 ID A-014VOTE · 0.97
Perception for living systems
AI systems from the physical world.
During my PhD, I built robotic and computer-vision systems to solve problems in real agricultural fields.
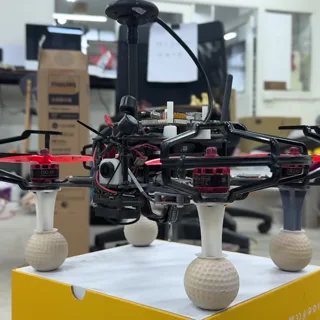
01 · Autonomous UAV sensing
A flight stack built for the places GPS cannot reach.
-
From sim to real
-
Autonomous mission execution
-
Turning a mission into a 3D scene
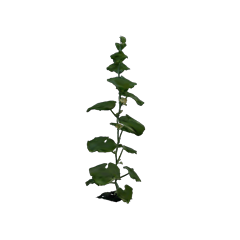
02 · 3D plant phenotyping
From an autonomous flight to organ-level growth curves.
-
Individual plant extraction and reconstruction
precision 0.933 · mIoU 0.890
-
3D organ segmentation
PTv3 point clouds · mean AP50 0.924
-
Across-days monitoring
198 plant-days · logistic R² 0.998
Row B · plant 01 · 3DGS · DAT 24
03 · High-resolution pest sensing
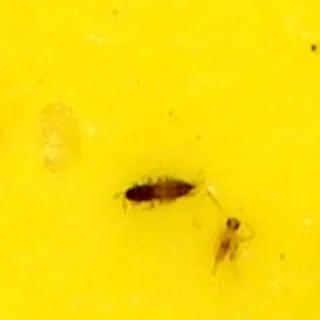
An imaging system that makes pest management measurable.
-
Image analysis for sub-millimetre pests
targets under 1 mm · scanners that vary from user to user
-
A recognition system built to keep iterating
built with cross-domain experts · simple enough to run on site

real scan above · schematic below
04 · Cattle edge intelligence
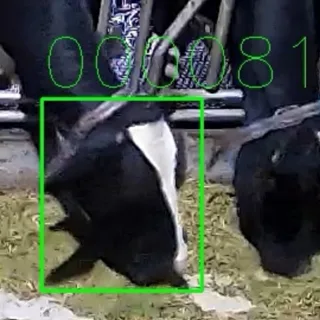
From a tracked face to an individual behavior record.
-
Cattle identity at the edge
tracked ROI · 512-D face embedding · temporal identity vote
-
Field system architecture
multi-camera + IoT · local inference · event-only telemetry
ID A-014VOTE · 0.97
 ID B-087VOTE · 0.95
 ID C-203VOTE · 0.96
 ID D-316VOTE · 0.94
Field inputs
CAMMULTI-CAM
IoTMICROCLIMATE
VISION
DETECTROI›
TRACKASSOCIATE›
RE-IDEMBED
VOTE
VOTE
IoT
INGEST › NORMALIZE › FUSE
INDIVIDUAL EVENTIDENTITY · DURATION · BEHAVIOR · THI
Data layer
EVENT STOREON SITE
CLOUDSECURE
USER
BEHAVIOR
ENVIRONMENT
ENVIRONMENT
VIDEO REMAINS AT EDGE · ONLY STRUCTURED EVENTS LEAVE SITE
tracked ROI → 512-D embedding → identity match
At a glance
Research depth, product habits.
Publications
- From 3DGS scenes to plant traits: a scalable extraction and segmentation framework for muskmelon phenotypingFrontiers in Plant Science · 2026
- Development of a visual SLAM-based autonomous UAV system for greenhouse plant monitoringDrones · 2026
- PhD thesis — Autonomous vision-based UAV system for 3D phenotyping and growth monitoring of greenhouse muskmelonNational Taiwan University · 2026
Ongoing projects
- Individual-level temporal phenotyping of greenhouse vine cropsmanuscript in preparation
- Video-to-3DGS reconstruction toolframes → SfM → Gaussian Splatting, CLI + GUI
- Shared visual canvas for coding agentsthink through a project on one board with an agent
Field deployments
- Greenhouse muskmelon, NTU experimental farmautonomous UAV + 3DGS phenotyping, multi-season, 198 plant-days
- Pest imagingscanner-based sticky-trap pipeline, built to run on site
- Cattle barnmulti-camera edge system, video never leaves the site
Stack
3DGS · COLMAP · SAM3 · PyTorch · Point Transformer · ROS2 · PX4 · FastAPI · PyQt · Docker
Education
PhD, Bio-Industrial Mechatronics Engineering, National Taiwan University (2026). Advisor: Ta-Te Lin. Research spanned autonomous UAV sensing, visual SLAM, and 3D plant phenotyping from Gaussian Splatting reconstructions, taken from simulation to working greenhouse deployments.